Don’t Run with Scissors: Pruning Breaks VLA Models
but They Can Be Recovered

Jason Jabbour1,2, Dong-Ki Kim1, Max Smith1, Jay Patrikar1, Radhika Ghosal2,
Youhui Wang2, Ali Agha1, Vijay Janapa Reddi2, Shayegan Omidshafiei1

1FieldAI 2Harvard University

Conference on Robot Learning (CoRL) 2026

Pruning severely degrades VLA task success and safety.

Dense weightsScroll to prune

Representative VLAs such as OpenVLA and NaVILA, when pruned with Magnitude or Wanda, drop in task success rate to 0% (from 85.2% and 43.0%, respectively). Pruning also increases unsafe behavior: OpenVLA’s unsafe-episode rate rises from 33.4% to 51.6%, and NaVILA’s from 23.0% to 100.0%.

What that degradation means for a robot.

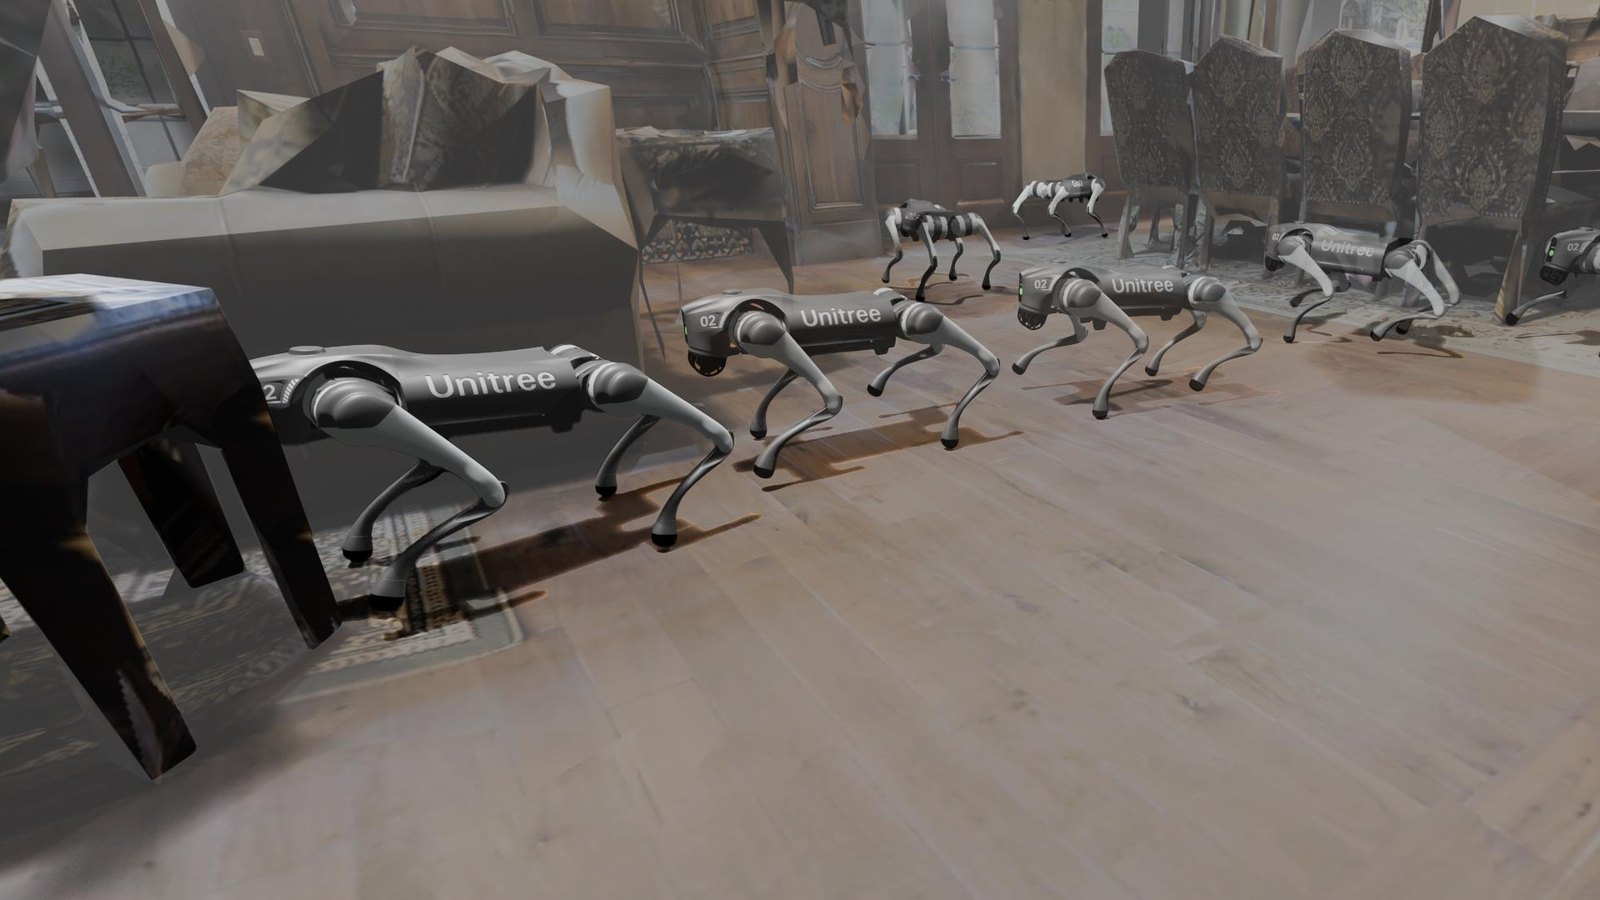
Instruction“Enter the dining room and walk to the other end.”
A Unitree Go2 quadruped walking through a dining room. The pruned VLA’s purple path turns into a table and ends at an X; the orange GLUESTICK path continues to the far end of the room.
Colliding with an object.
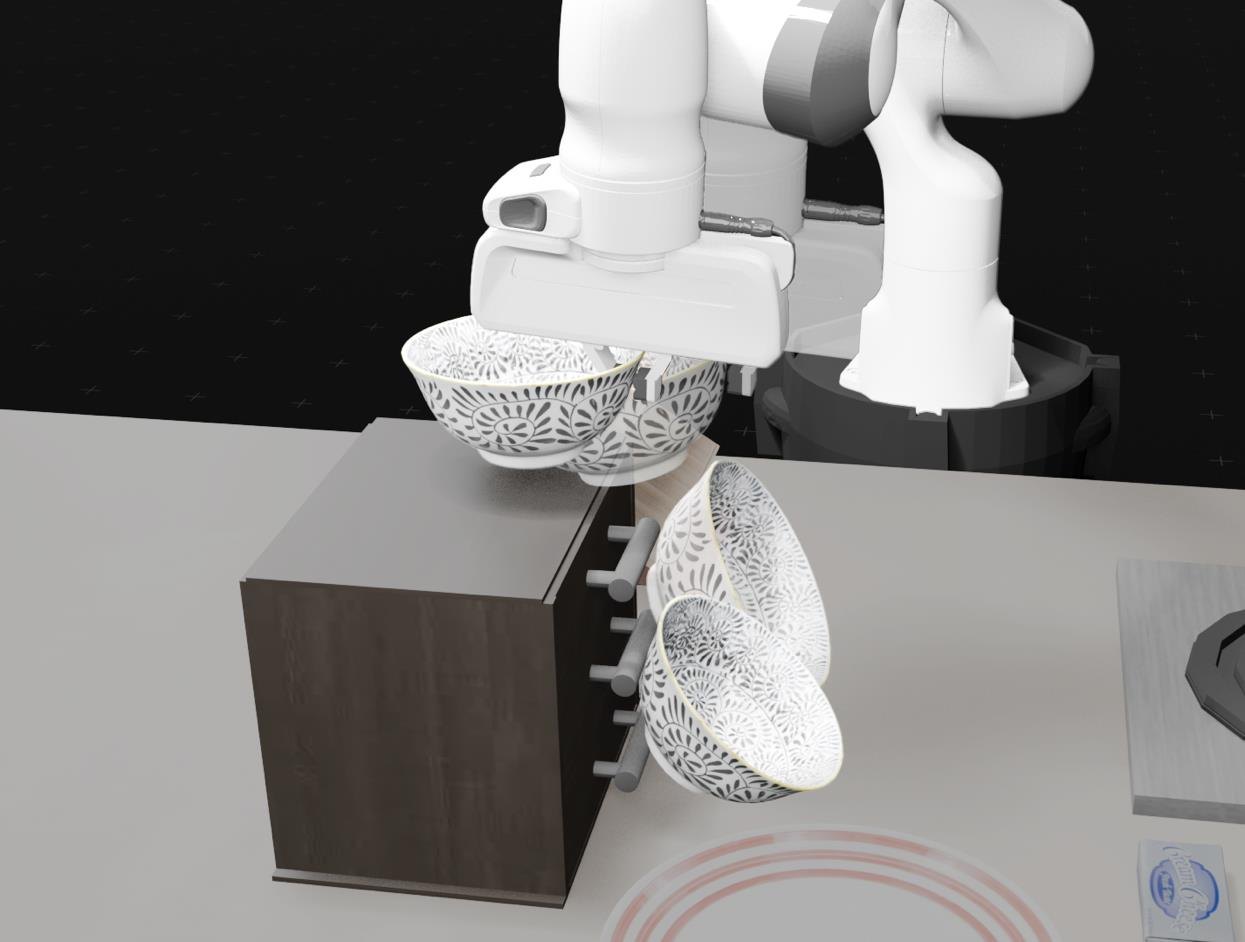
Instruction“Put the bowl on top of the cabinet.”
A robot arm holding a bowl above a cabinet. The pruned VLA’s purple path drops the bowl to the floor and ends at an X; the orange GLUESTICK path places it on the cabinet.
Dropping a bowl.

We propose GLUESTICK.

  • Post-pruning
  • Training-free
  • Pruning-algorithm agnostic
  • Largely retains memory and speed benefits

Take a look.

Pruned
With GLUESTICK
Instruction“Enter the dining room and walk to the other end.”

Colliding with an object.

Reaches the other end safely.

Instruction“Put the bowl on top of the cabinet.”

Dropping a bowl.

Places the bowl on the cabinet.

How GLUESTICK works.

OfflinepruningScroll to step through

GLUESTICK starts from the dense VLA model and iterates through its linear layers.

Each layer is pruned with any algorithm, ratio and pattern; we recommend 2:4 structured sparsity for hardware acceleration.

The gap between the dense and pruned weights captures the information lost to pruning.

A truncated SVD of the gap keeps its top r components as two lightweight matrices, A and B.

At inference, each layer keeps its sparse weights unchanged and adds a lightweight low-rank correction, restoring the lost signal at minimal cost.

  • Needs only the dense model and its pruned counterpart
  • One-time offline cost
  • No additional training

On a real robot.

Unitree G1 humanoid running GR00T N1.7, pruned with Magnitude at 50% 2:4 sparsity.

Instruction“Pick up the apple and place it in the bin.”
Pruned
Self-collision
Containment breach

Safety monitor

Self-collisionClearViolated at 0:08
End-effector containmentClearViolated at 0:44

EpisodeIn progressFailed

With GLUESTICK

Safety monitor

Self-collisionClearViolated at 0:08
End-effector containmentClearViolated at 0:44

EpisodeIn progressSucceeded

It holds up across sparsities, pruning methods and models.

Across sparsities

Method0%30%50%70%
Wanda85.280.831.81.2
+ GLUESTICKn/a85.860.224.6

Table 8. GLUESTICK-500’s recovery of VLA success rates across sparsities. Evaluated on LIBERO Spatial. Results for the pruned language backbone of OpenVLA using Wanda.

On VLMs

Method0%30%50%70%
Wanda93.8893.3888.1621.30
+ GLUESTICKn/an/a92.9590.89

Table 9. GLUESTICK-500’s ability to recover pruned VLM performance. Evaluated on 1000 DocVQA examples using Wanda-pruned Qwen2-VL-7B-Instruct VLM. Values show ANLS.

Across pruning algorithms and patterns

Method2:44:8
Magnitude11.025.4
+ GLUESTICK48.861.8

Table 10. GLUESTICK is pruning-algorithm and sparsity-pattern agnostic. Magnitude-pruned OpenVLA language backbone evaluated on LIBERO Spatial (values show success %).

Read the paper.

Full results, ablations, and real-world experiments.

Read on arXiv

arXiv:2510.08464 · CoRL 2026